One thing I love about FPV is how quickly the hobby evolves. Every few months, someone would come up with a new way to build a quad: cleaner wiring, less weight, better vibration isolation, easier repairs, more integration, you name it. Some ideas become new standards. Others become popular for a short while and then quietly disappear. That does not necessarily mean they were bad ideas. Sometimes technology simply moved in another direction. Sometimes another solution became cheaper or easier. And occasionally, an idea was probably just a few years ahead of its time. Here are some of the most interesting FPV trends that disappeared, or at least never became mainstream.


New to FPV? Here’s a collection of guides on how to build an FPV drone from scratch: https://oscarliang.com/how-to-build-fpv-drones/
Table of Contents
Angled Motor Mounts

This one takes me right back to the early days of FPV racing in 2014.
Instead of mounting all 4 motors flat on the arms, people added wedges underneath them so the motors tilted forward.

The idea was actually quite clever.
When a quad flies forward quickly, the entire aircraft has to pitch forward. That is why racing quads need such extreme FPV camera angles, sometimes as high as 50° or 60° upwards just so you can see the horizon at full speed. Here’s a discussion about camera tilt angle: https://oscarliang.com/camera-angle/
By tilting the motors forward, the quad could generate forward thrust without pitching the whole body quite as far. There was also a potential aerodynamic benefit because the body could remain more level at speed, reducing air resistance. Angled motor mounts were genuinely popular accessories around 2014 to 2015.
So why did they disappear?
Mostly because the additional hardware, weight and complexity were not really worth it. Racing frames got lighter and more aerodynamic. And pilots simply got used to flying with aggressive camera tilt.
Custom Made PDB Extension Board for Frames
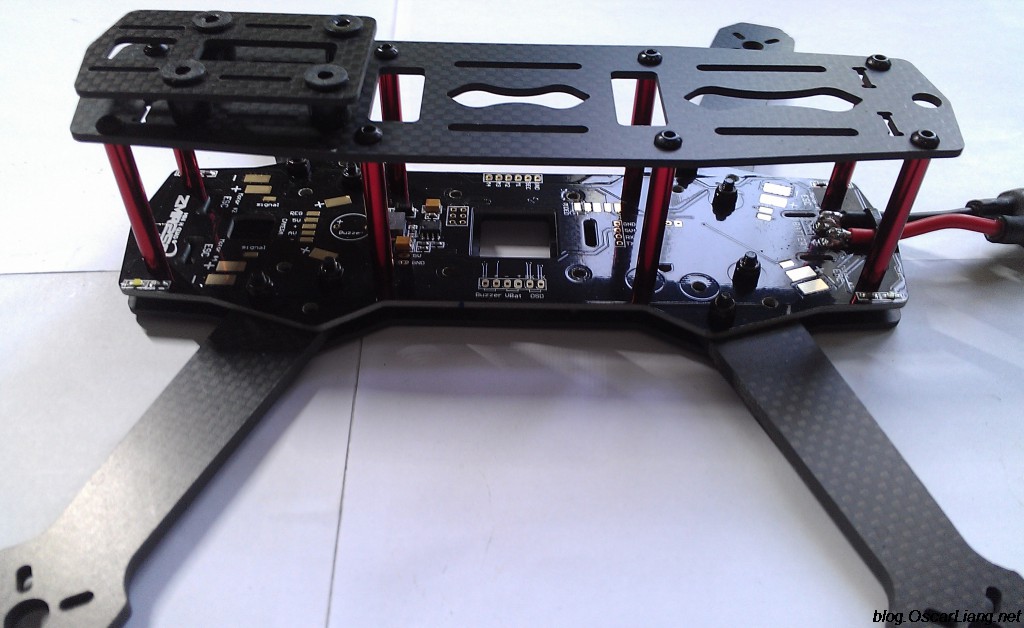
There was a period when only a handful of FPV drone frames were really popular, and manufacturers started making custom PCBs shaped exactly like the bottom plate of those frames, allowing you to solder all your electronics directly onto them.
The most notable example was the ZMR250. It was a clone of the iconic Blackout Mini H frame, but because it was much cheaper and more accessible, it became arguably the most popular FPV frames at the time.
Manufacturers came up with a clever idea: replace the bottom plate with a custom shaped PDB (Power Distribution Board). You could solder all your separate components directly to it, including the FC, BEC, ESCs, XT60 battery lead, camera, OSD, VTX, receiver and buzzer.

At the time, this looked like the future. It made builds incredibly clean because much of the wiring disappeared.
The problem was compatibility. These PDBs were only available for a small number of specific frames, so they limited your frame choices. Now, there are more frames than I can count, it’s just not practical anymore. Check out my frame recommendations: https://oscarliang.com/fpv-drone-frames/
FCs and ESCs also became increasingly integrated. Modern flight controllers include components like BECs, current sensor and OSD, while 4in1 ESCs handle power distribution as well. There is simply much less need for a separate PDB anymore.
But man, I was really impressed by how clever this idea was when I first saw it :)
Soft-Mounted Motors

Around 2017, soft mounting became a huge topic.
Powerful motors, higher gyro sampling rates and increasingly aggressive PID looptime made vibration and gyro noise a serious concern. One proposed solution was to physically isolate the motors from the frame using rubber, TPU, foam or other damping material.
Yes, we literally went as far as soft mounting the motors! :D
The idea made sense: if the motor is producing vibration, stop that vibration from entering the frame in the first place. But it also introduced other problems. Motor screws could loosen (because you have to avoid overtightening them for the soft mounting to work effectively), the mounts added weight and complexity, and damping the motor itself was not always necessary.
What really killed the trend was
- flight controller manufacturers began soft mounting gyros, and eventually the entire FC with rubber grommets.
- also software filtering in Betaflight got so much better over the years. Learn how to tune filters here: https://oscarliang.com/pid-filter-tuning-blackbox/
The Modular 4in1 ESC


The Quarant 25A ESC was perhaps the first, and the last, tried to combine the flexibility of individual ESC, with the convenience of 4in1 ESC.
They are basically single ESC’s, but you can assemble four of them into a 4in1 ESC.
On paper, it gave you the best of both worlds:
- Need individual ESCs for an unusual aircraft? Use them separately.
- Want to mount your ESC under the FC in a stack? Sure, just solder 4 of them together.
- Burn one ESC? Replace that module instead of throwing away an entire 4in1 board.
The problem was that conventional 4in1 ESCs became extremely affordable, reliable and compact. Eventually 4in1 ESC became mainstream. Individual ESCs, once standard on FPV quads, have now largely become a niche option today.
Two Cameras in One Unit

Before digital FPV became mainstream, there was always a compromise between low latency FPV video and high quality HD recording.
Action cameras could record beautiful footage but often had too much latency to use as the actual FPV feed.
So manufacturers came up with another solution: put two sensors in the same camera module:
- One camera was for the low latency analog FPV feed.
- The other recorded 1080p, or even 4K HD footage on an SD card.
The RunCam Hybrid was probably one of the best known implementations back in 2019.
So why did it disappear? Mainly because of Digital FPV systems.
Systems like DJI O4 Pro can provide the FPV feed while also recording high resolution video onboard. Meanwhile, pilots who demand the very best image quality still tend to carry a dedicated camera like the DJI Action 6.
3D FPV Cameras

This one sounded incredibly futuristic.
Instead of a single FPV camera, you mounted two cameras separated slightly apart, mimicking human eyes. The system sent stereoscopic video to compatible VR goggles, allowing you to perceive depth rather than looking at a flat image.
Basically, actual 3D FPV, and it worked.
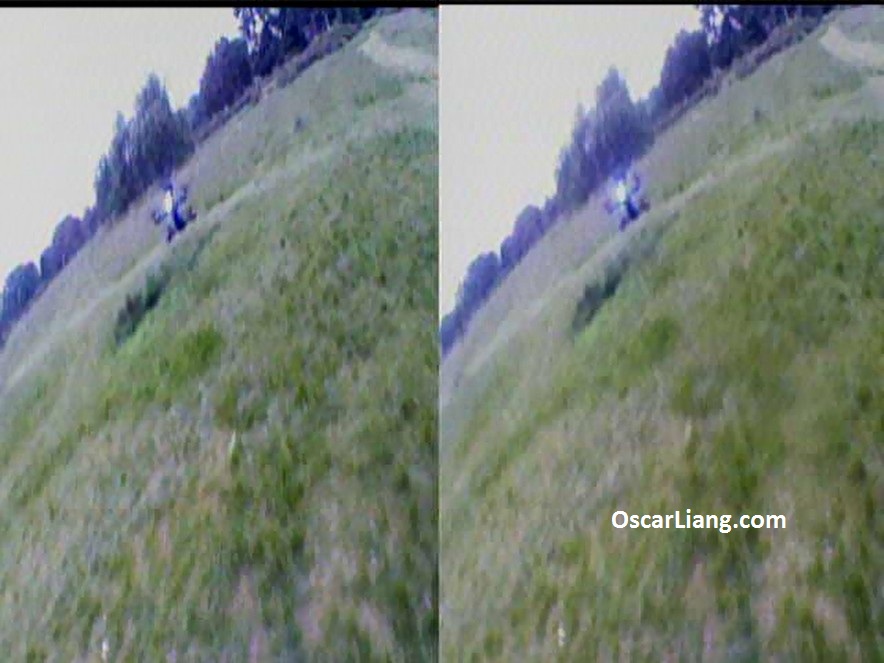
For proximity flying, depth perception sounds fantastic. Being able to judge the distance between your quad and a branch should theoretically feel much more natural and connected.
Unfortunately, the entire system became more complicated.
You needed two cameras, special video processing, transmission, and compatible goggles. It added cost, weight and complexity to solve something our brains are already surprisingly good at estimating using motion, perspective and experience.
Regular FPV also kept improving in resolution, field of view and latency.
3D FPV never completely vanished as an experiment, but it certainly never became the revolution people once imagined. Maybe VR style FPV will return one day. The idea still has potential.
Modular Flight Controller Stack

The Chickadee Polystack might be my favourite idea on this list.
Back in 2016, instead of putting every possible feature onto one flight controller board, Chickadee created a modular ecosystem.
You started with the FC and then stacked additional boards, or “mods”, depending on what you actually needed. It’s like Lego!
- Want More Blackbox storage? Add the micro SD card module.
- Want to use a receiver? Add another module for that specific receiver.
- Need more serial connections? Add a breakout module.
All the boards had high density connectors, and were plug and play. You could connect multiple modules in the same stack. And it was also open-source.
I reviewed Polystack back in 2016 and thought the concept was fantastic. The philosophy made perfect sense: why replace an entire flight controller just because you want one extra feature, or a different feature?
Unfortunately, modularity costs money and takes space. The FC itself was already relatively expensive, and then you had to buy the additional modules you needed. If you need a lot of features, the stack took a lot of space.
At exactly the same time, normal flight controllers were packing more and more features. OSD, BECs, barometer, Blackbox Memory, and loads of UARTs gradually became standard features on a single inexpensive PCB. Check out my FC recommendations: https://oscarliang.com/flight-controller/
Final Thoughts: Bad Ideas, or Just Ideas from the Wrong Time?
Looking back at all these forgotten FPV trends, I do not think most of them were bad ideas. Many were attempts to solve genuine problems.
What killed many of them was simply integration. Instead of adding more specialized hardware, the components we already had became capable of doing even more.
That seems to be the recurring direction of FPV: fewer boards, fewer wires, fewer connectors and more functionality packed into each component.
But FPV also has a habit of recycling old ideas. With increasingly powerful electronics, I would not be surprised if some of these old concepts eventually return in a completely different form. Sometimes an FPV trend disappears because it was a dead end. And sometimes it was simply ten years too early.
Did I miss other popular trends that later disappeared? Let us know in the comments and get nostalgic together.